Overview
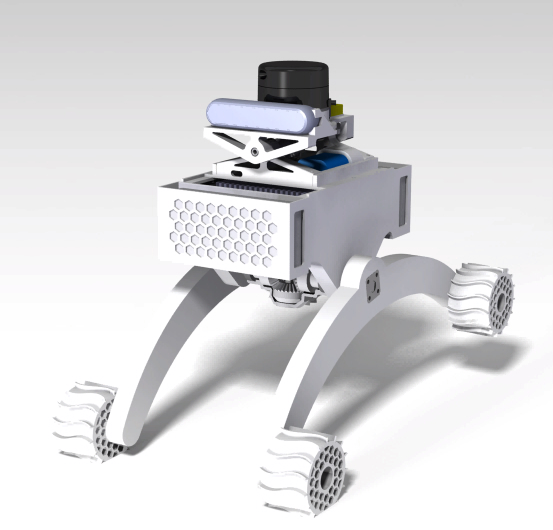
DARAM-G is a rover developed for autonomous exploration over uneven terrain. A custom rocker chassis enables the rover to traverse obstacles, while an IMU-stabilized, two-axis gimbal keeps the sensor platform level in roll and pitch as the rocker mechanism moves. The main body houses the computer and battery and uses a honeycomb structure to support heat dissipation.
The rover carries an RGB-D camera and a 2D LiDAR. Its ROS 2 autonomy stack integrates 2D LiDAR SLAM, LiDAR odometry, frontier-based exploration, and Nav2, together with semantic information derived from RGB-D observations.
The software was validated in a custom Gazebo simulation environment. The team also built the physical rover and conducted real-world experiments to evaluate the integrated system.
Award
DARAM-G received the Hanwha Aerospace CEO Award at the 2025 National University Capstone Design Competition, hosted by The Society for Aerospace System Engineering (SASE).
The official competition page provides the event and award information.
Code
The code is available in the v1 branch.