Hoyun Kim

Master’s student · APRL, DGIST

I received my bachelor’s degree in Aerospace Engineering from Inha University. I am now a master’s student at DGIST in South Korea and a member of the Autonomy and Perceptual Robotics Lab (APRL).

My interests span Field Robotics, Aerospace Engineering, Sim2Real, and SLAM. I am particularly interested in building autonomous robotic systems that transfer capabilities developed in simulation to reliable operation in challenging real-world environments.

Hoyun Kim
DGIST · South Korea
hoyunkim@dgist.ac.kr

Recent News

  • Presented our work at the International Conference on Space Robotics (iSpaRo 2026).

  • Two papers accepted to iSpaRo 2026: MarsLab and our survey on planetary robotics simulation.

  • Presented our survey at the ICRA Workshop on Perceptual Challenges for Planetary Exploration.

  • Our planetary robotics simulation survey was accepted to an ICRA 2026 Workshop.

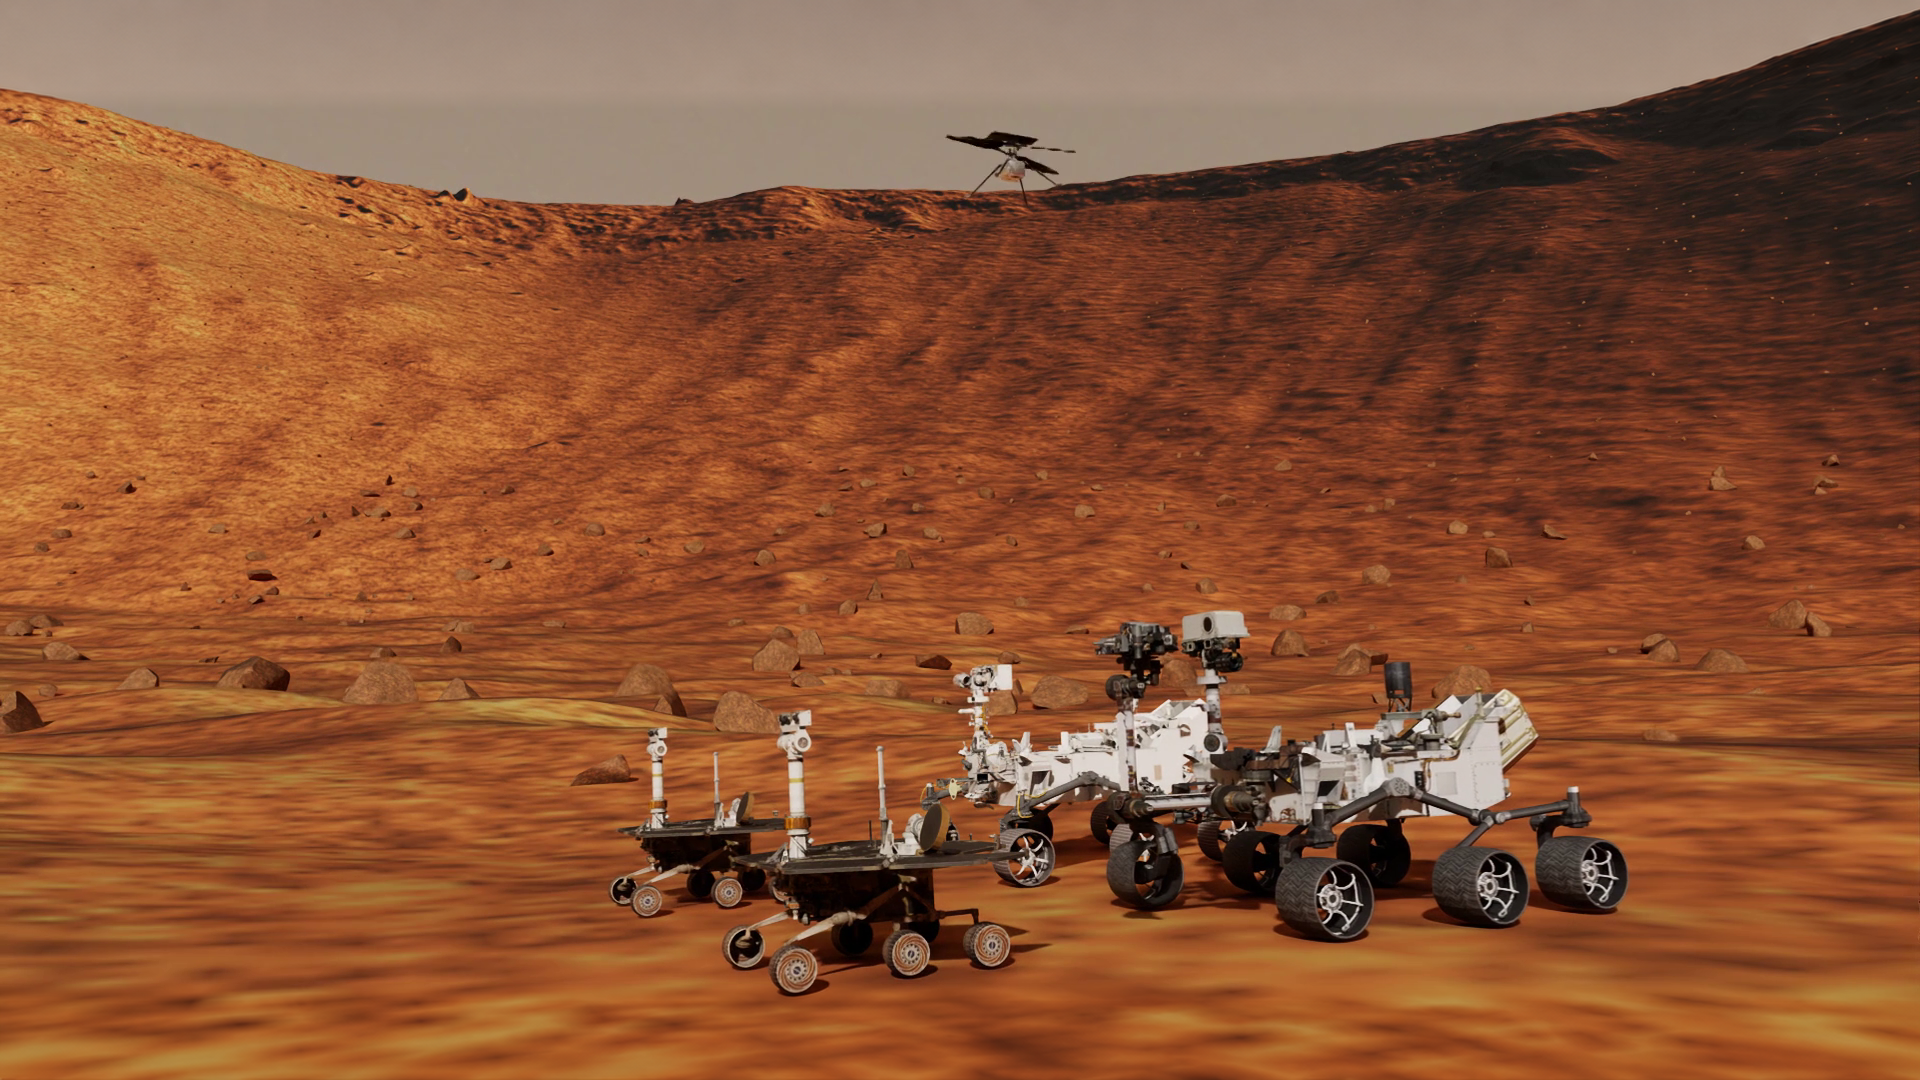
MarsLab showcase featuring Mars rover models and an aerial robot on Martian terrain

MarsLab: A Martian Rover Simulator for Planetary Rover Autonomous Navigation

Hoyun Kim, Beomsu Kim, Giseop Kim

International Conference on Space Robotics (iSpaRo), 2026

We present MarsLab, an open-source, ROS 2-native Mars rover simulator for repeatable autonomy evaluation. It provides customizable HiRISE-based terrain, lighting, dust, sensing, and rover motion, along with ground-truth pose data. It supports Perseverance, Curiosity, Opportunity, and Spirit rovers with a range of camera and LiDAR configurations.
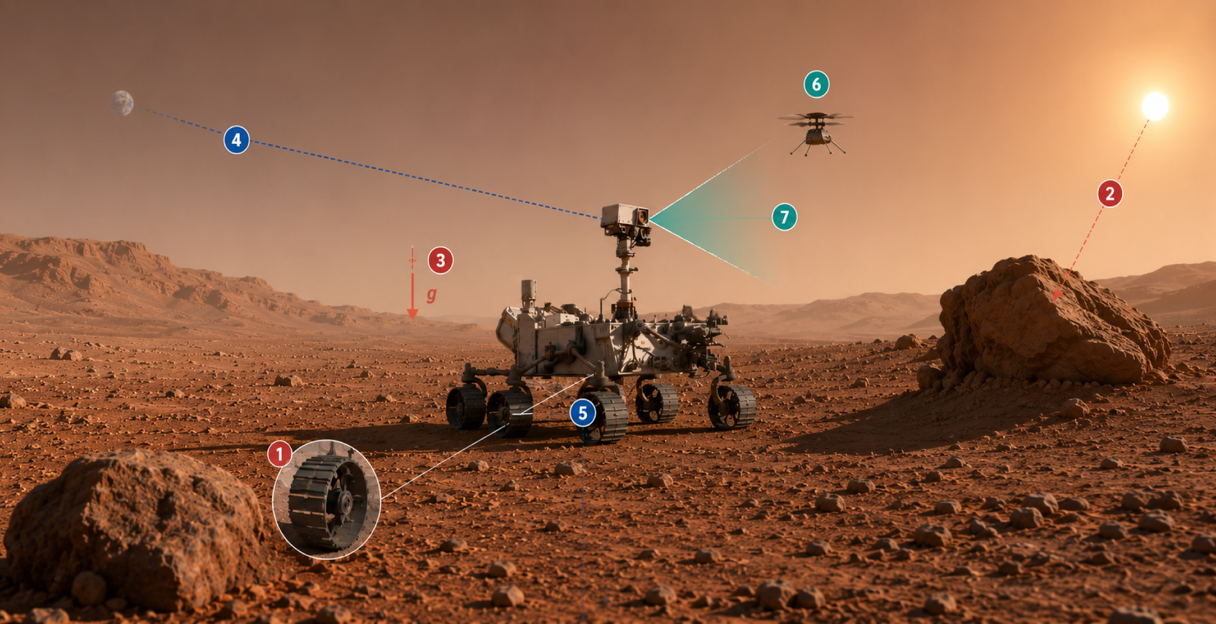
Overview of planetary robotics simulation factors around a rover and aerial robot

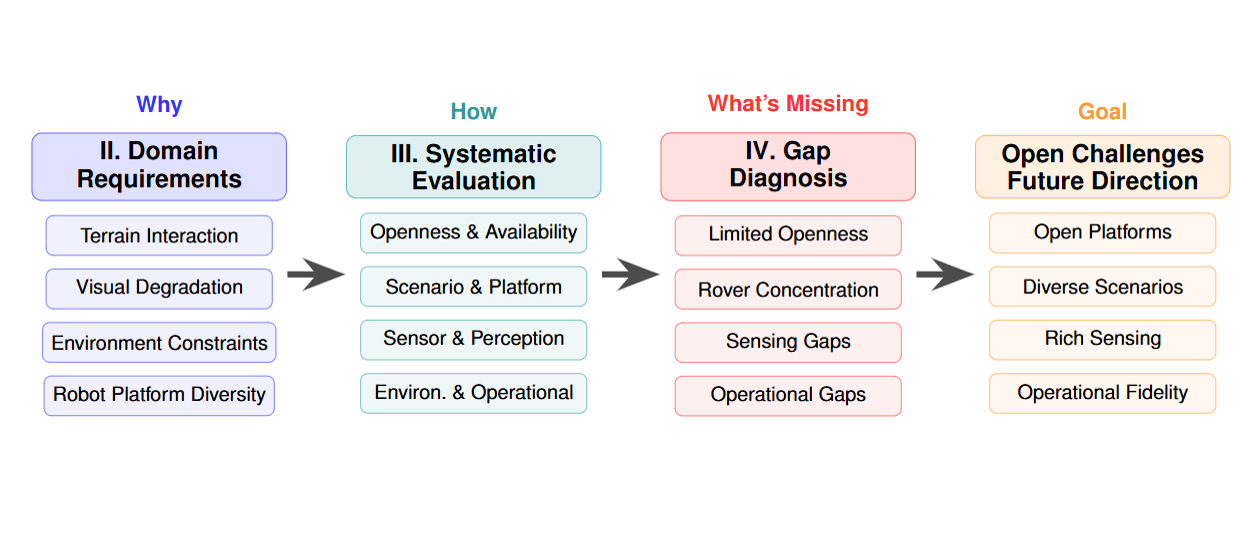
Simulation for Planetary Robotic Perception and Autonomy: A Concise Survey of Recent Capabilities and Gaps

Hoyun Kim, Giseop Kim

International Conference on Space Robotics (iSpaRo), 2026

We provide a simulation-centered perspective on recent work in planetary robotic perception and autonomy, organized around four practical axes: openness, scenario coverage, sensing support, and operational realism. Through this framework, we identify gaps in existing work and outline directions for future research.

2026

1 project
MarsLab showcase with Mars rover models and an aerial robot.

MarsLab

A ROS 2-native Mars rover simulator built on NVIDIA Isaac Sim, with continued upgrades planned including More realistic sensor simulation and Photorealistic Scene Generation.

Planetary roboticsIsaac SimROS 2Simulation

2025

4 projects
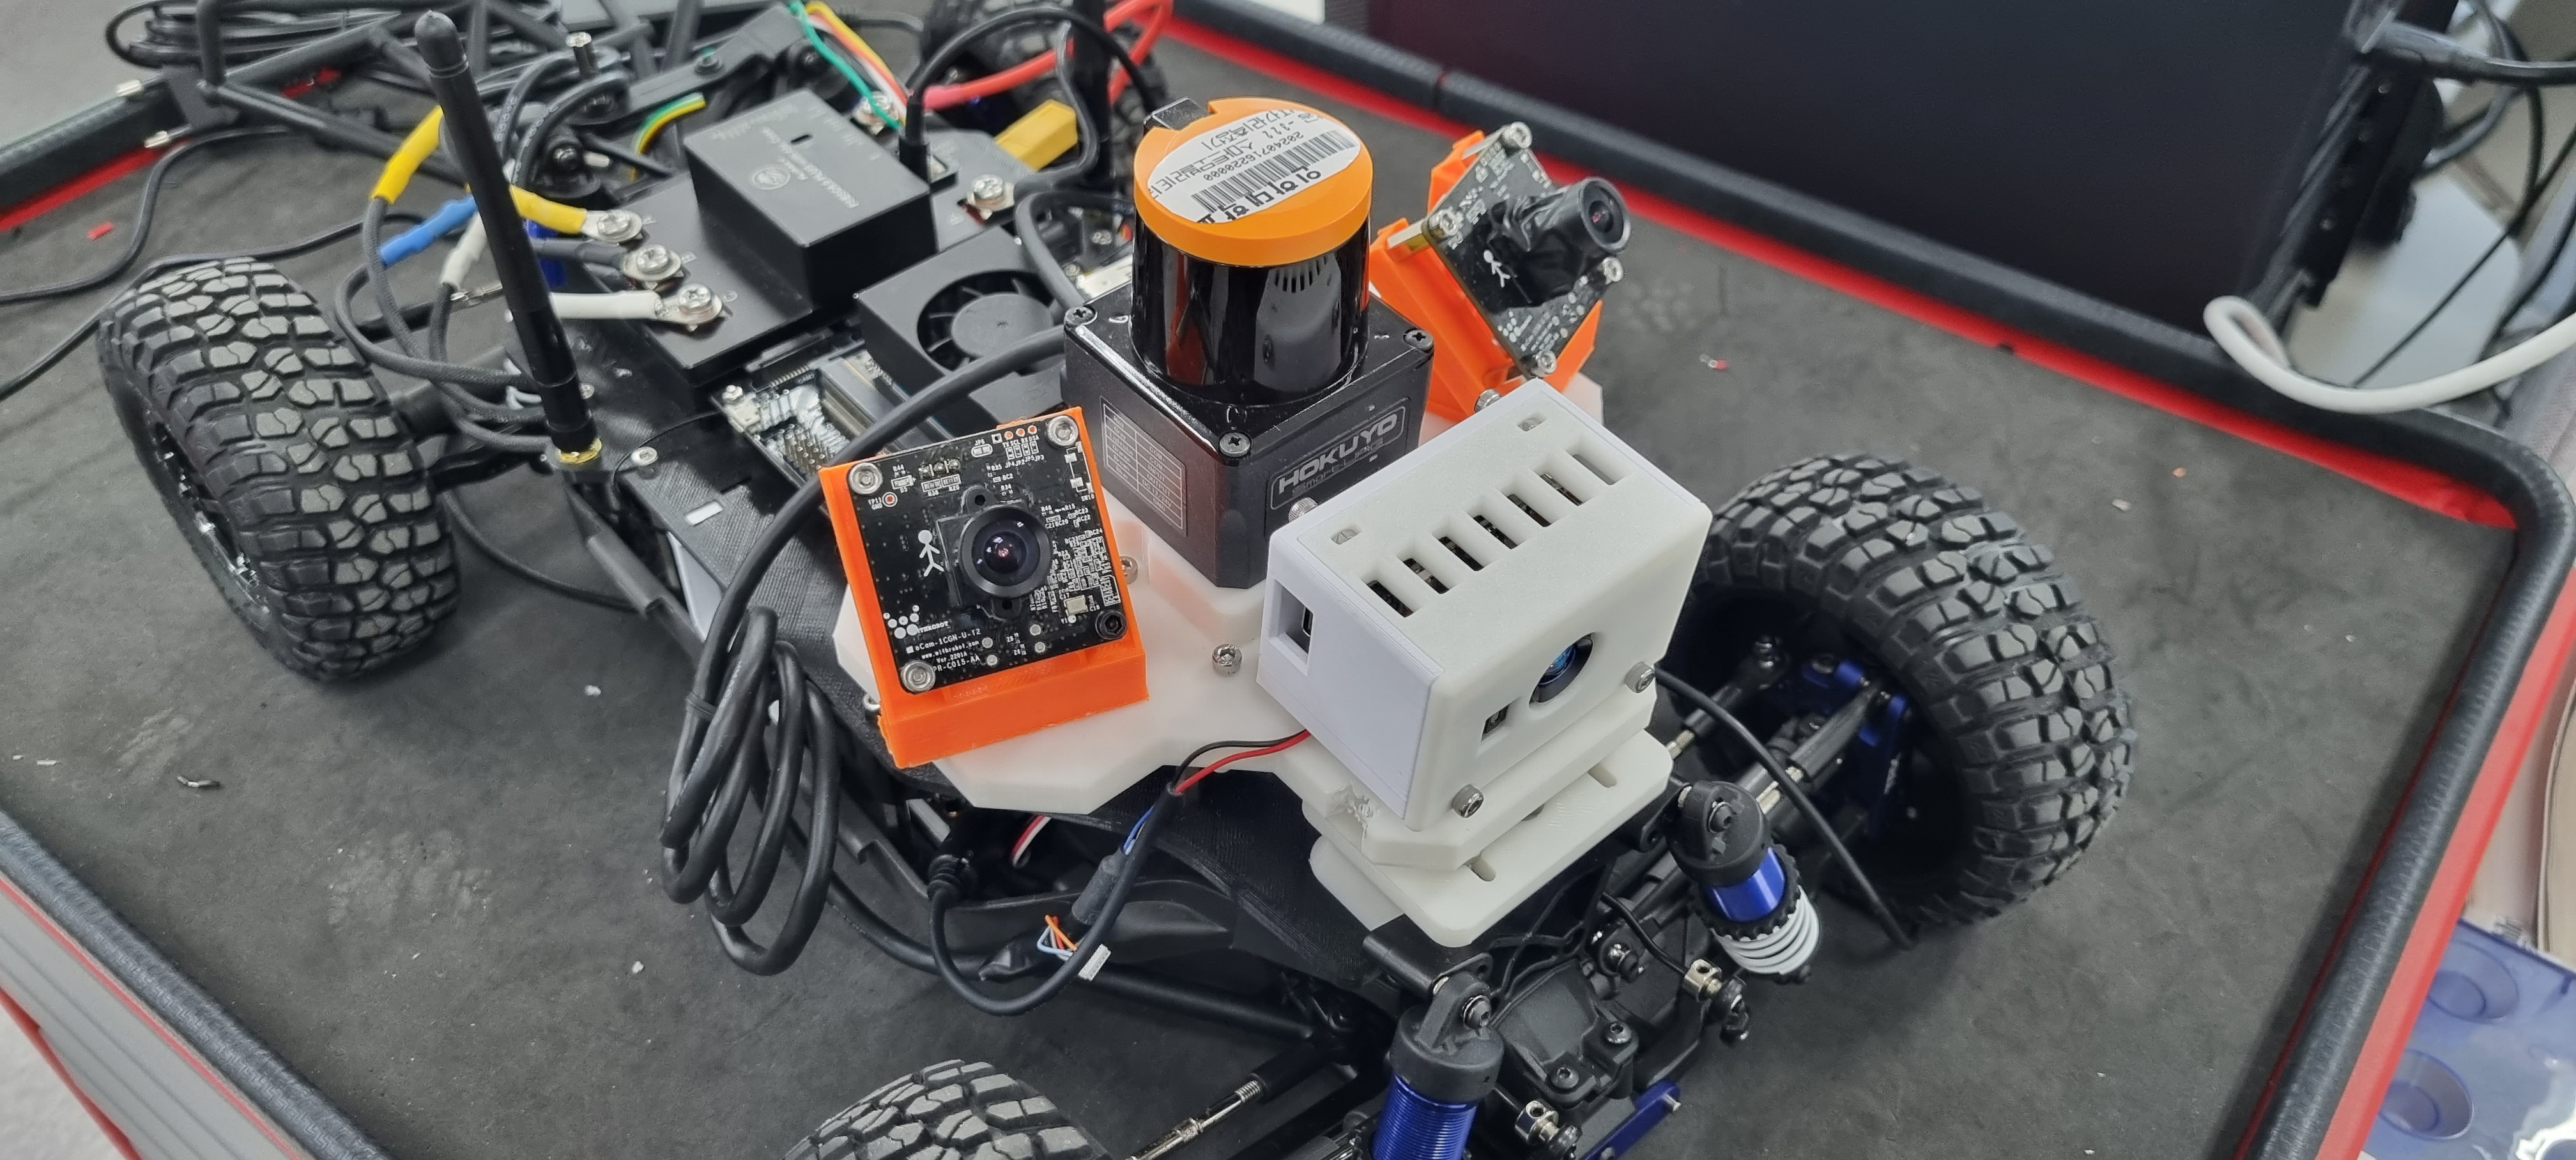
The F1TENTH autonomous racing project with RCV Formula.
Undergraduate project

F1TENTH

Autonomous racing software for RCV Formula, focused on SLAM and state estimation with 2D LiDAR, wheel odometry, and IMU measurements.

Former RCV Formula member; I am no longer affiliated with the team.

Autonomous racingF1TENTHROS 2
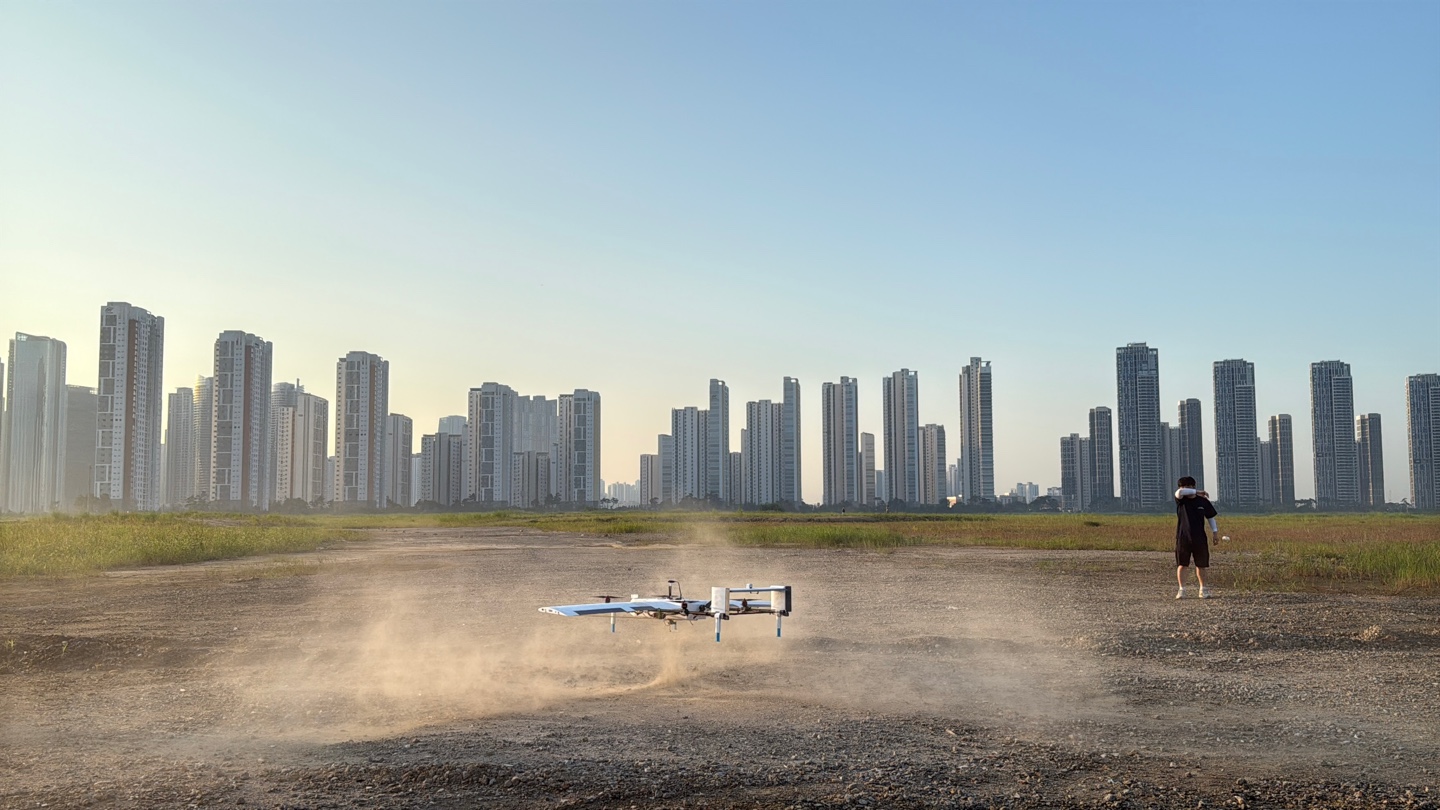
DOK4 during an outdoor aircraft flight test.
Undergraduate project

DOK4

A custom VTOL aircraft using ROS 2 and PX4 for autonomous search-and-rescue missions in the 23rd Robot Aircraft Competition in 2025.

Aerial roboticsPX4ROS 2
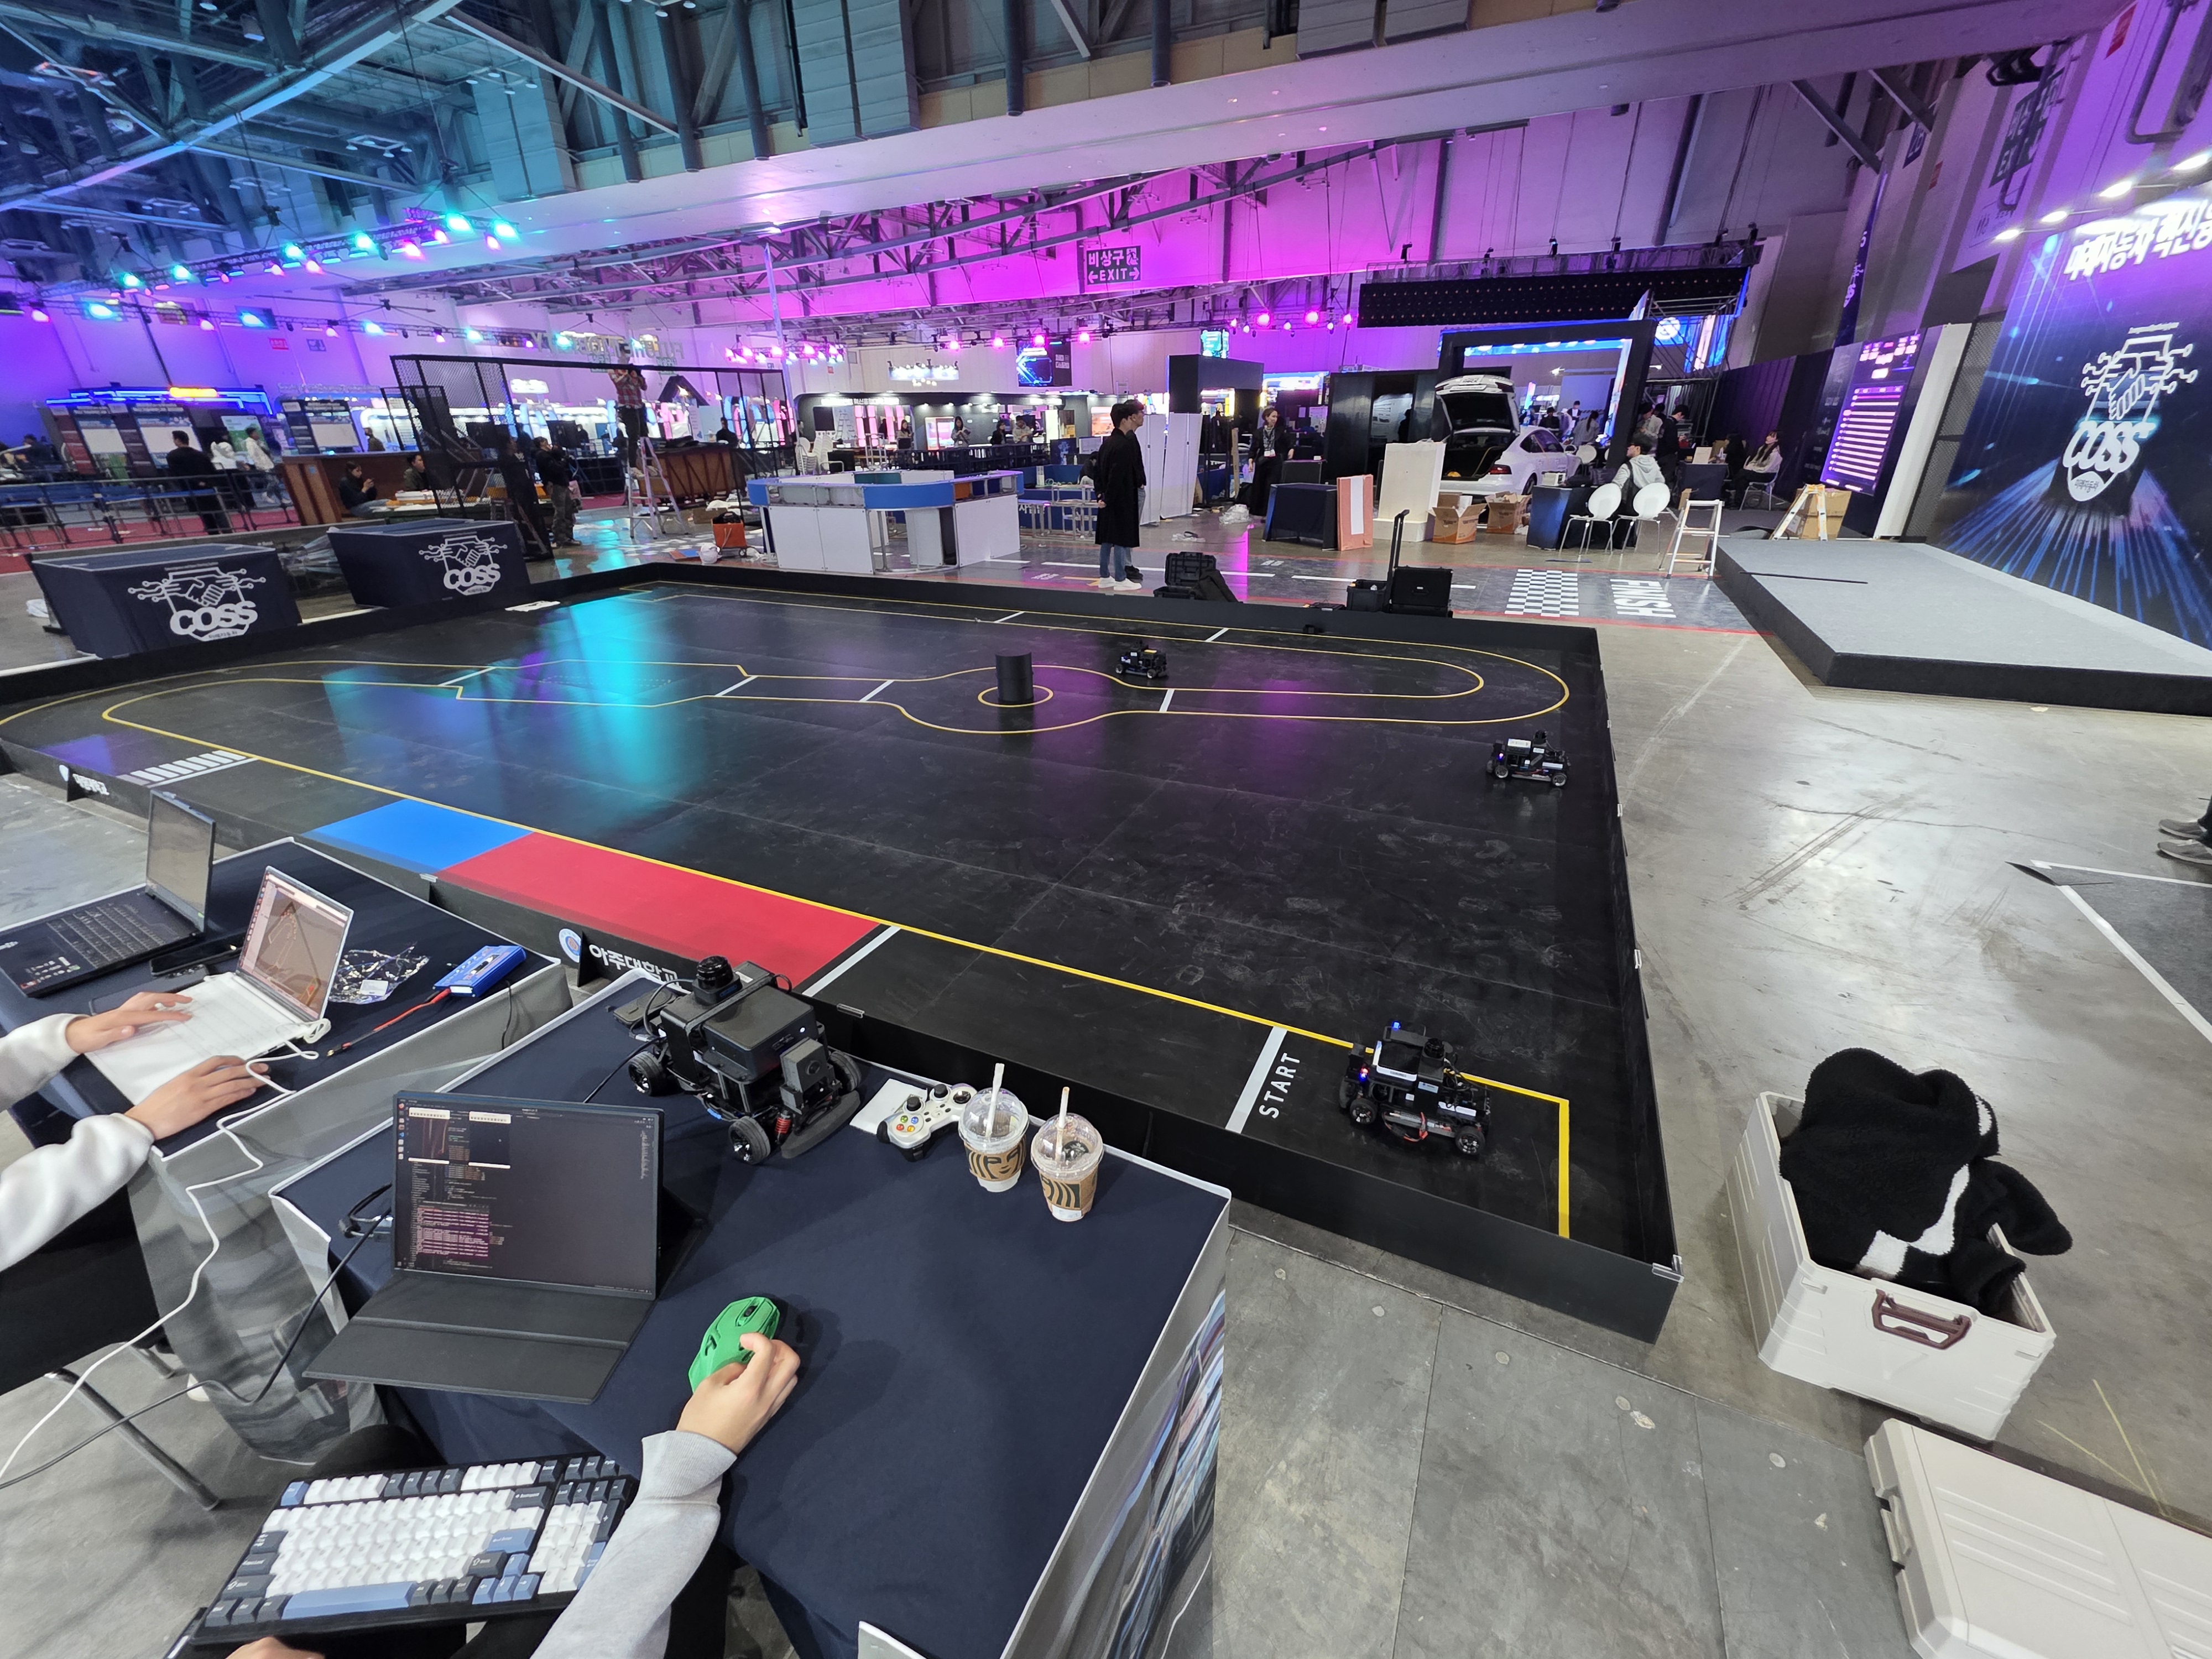
The Dudeoji scale-car autonomous driving project.
Undergraduate project

Dudeoji

A scale-car autonomous driving project entered in the 2025 AUTO RACE competition.

Autonomous drivingROS 2Gazebo
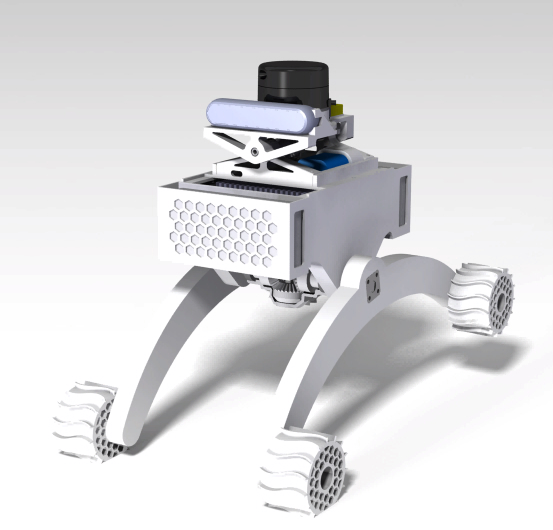
DARAM-G rover design with an RGB-D camera and LiDAR.
Undergraduate project

DARAM-G

An autonomous exploration rover with a rocker chassis, an IMU-stabilized sensor platform, and a ROS 2 autonomy stack for uneven terrain.

Hanwha Aerospace CEO Award

RoverAutonomous explorationSensor integrationROS 2

2024

1 project
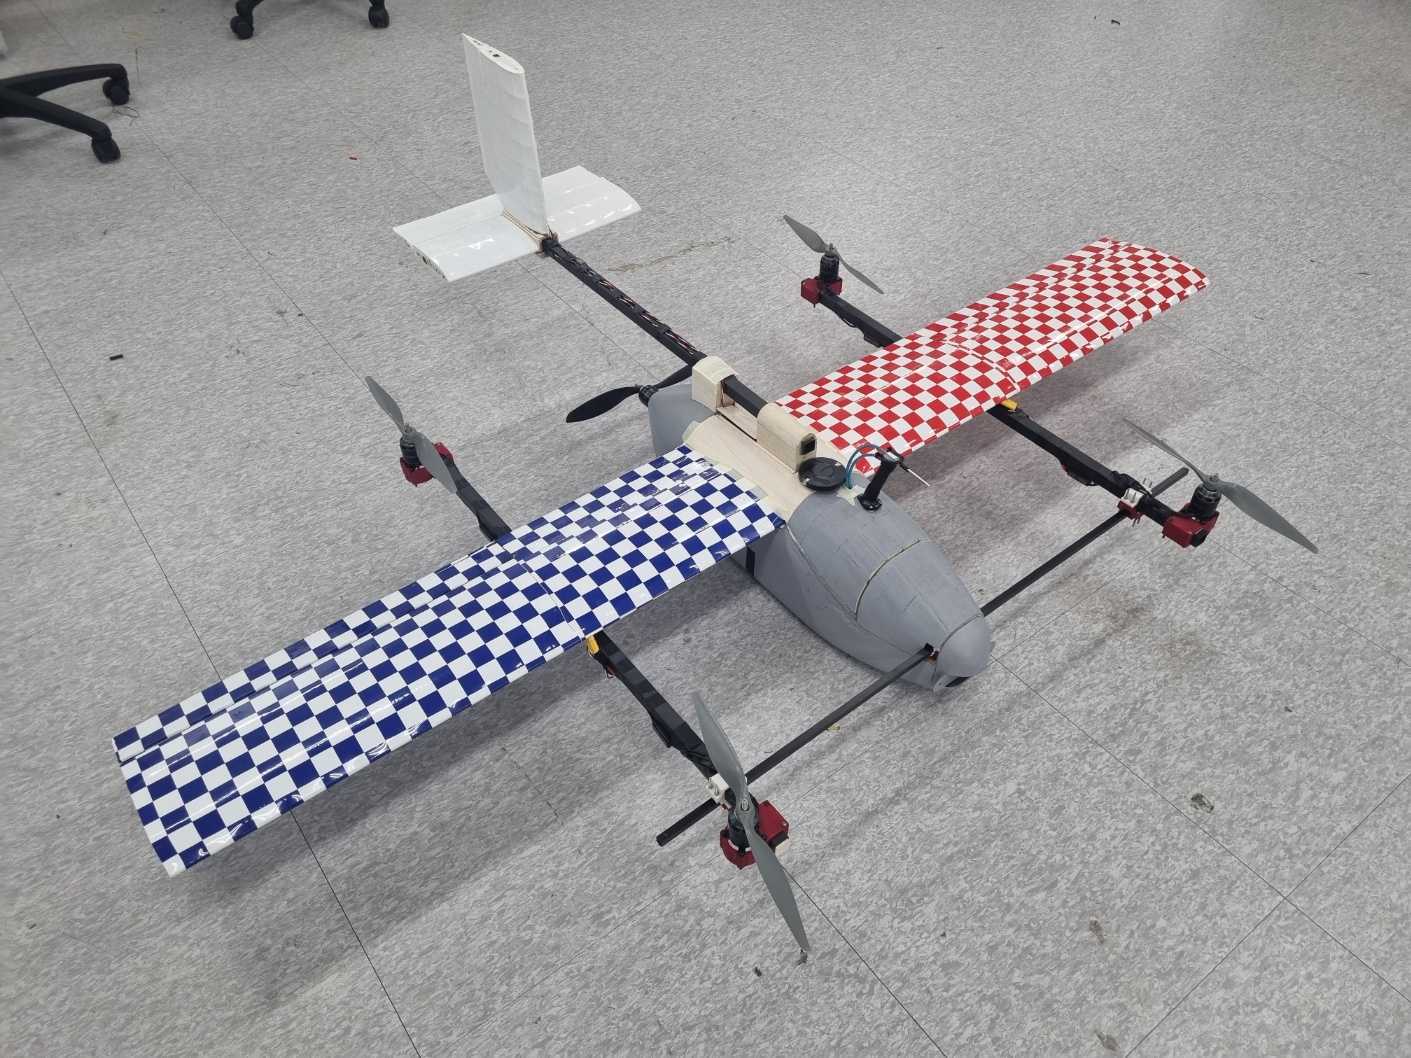
The InhaAerodream aircraft with its checkerboard-patterned wings.
Undergraduate project

InhaAerodream

A custom VTOL aircraft built with ROS 2 and PX4 for autonomous flight in the 22nd Robot Aircraft Competition in 2024.

Aerial roboticsPX4ROS 2

Research Notes

I also keep notes on papers, concepts, and things I learn along the way.

Explore Research Notes