MarsLab: A Martian Rover Simulator for Planetary Rover Autonomous Navigation
International Conference on Space Robotics (iSpaRo), 2026
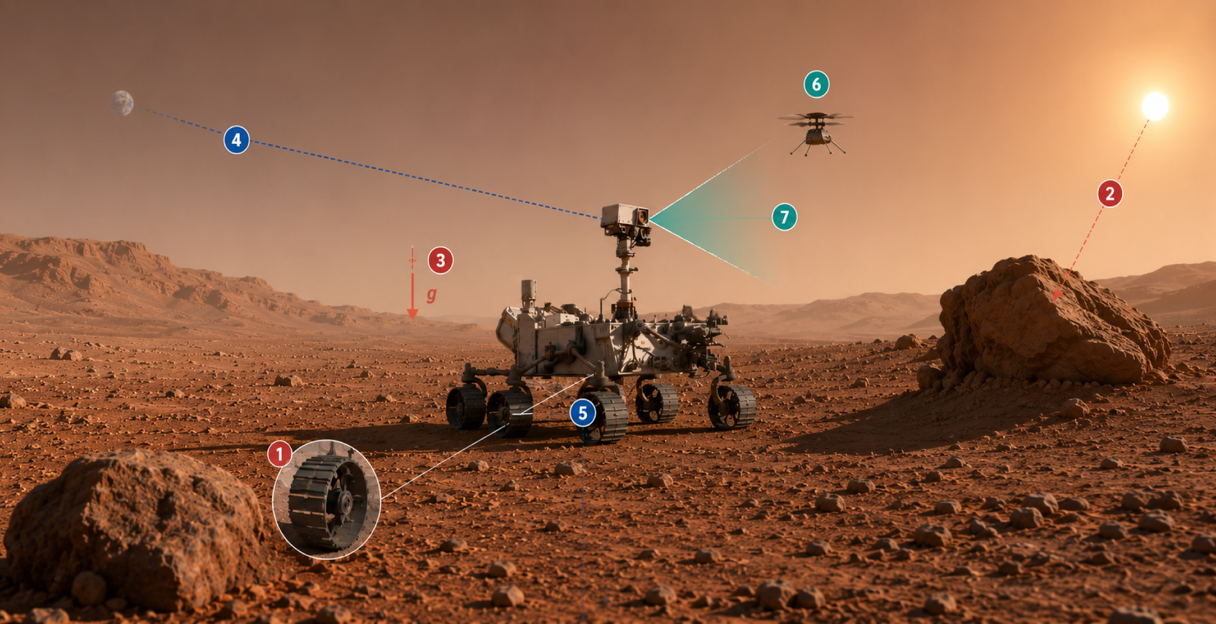
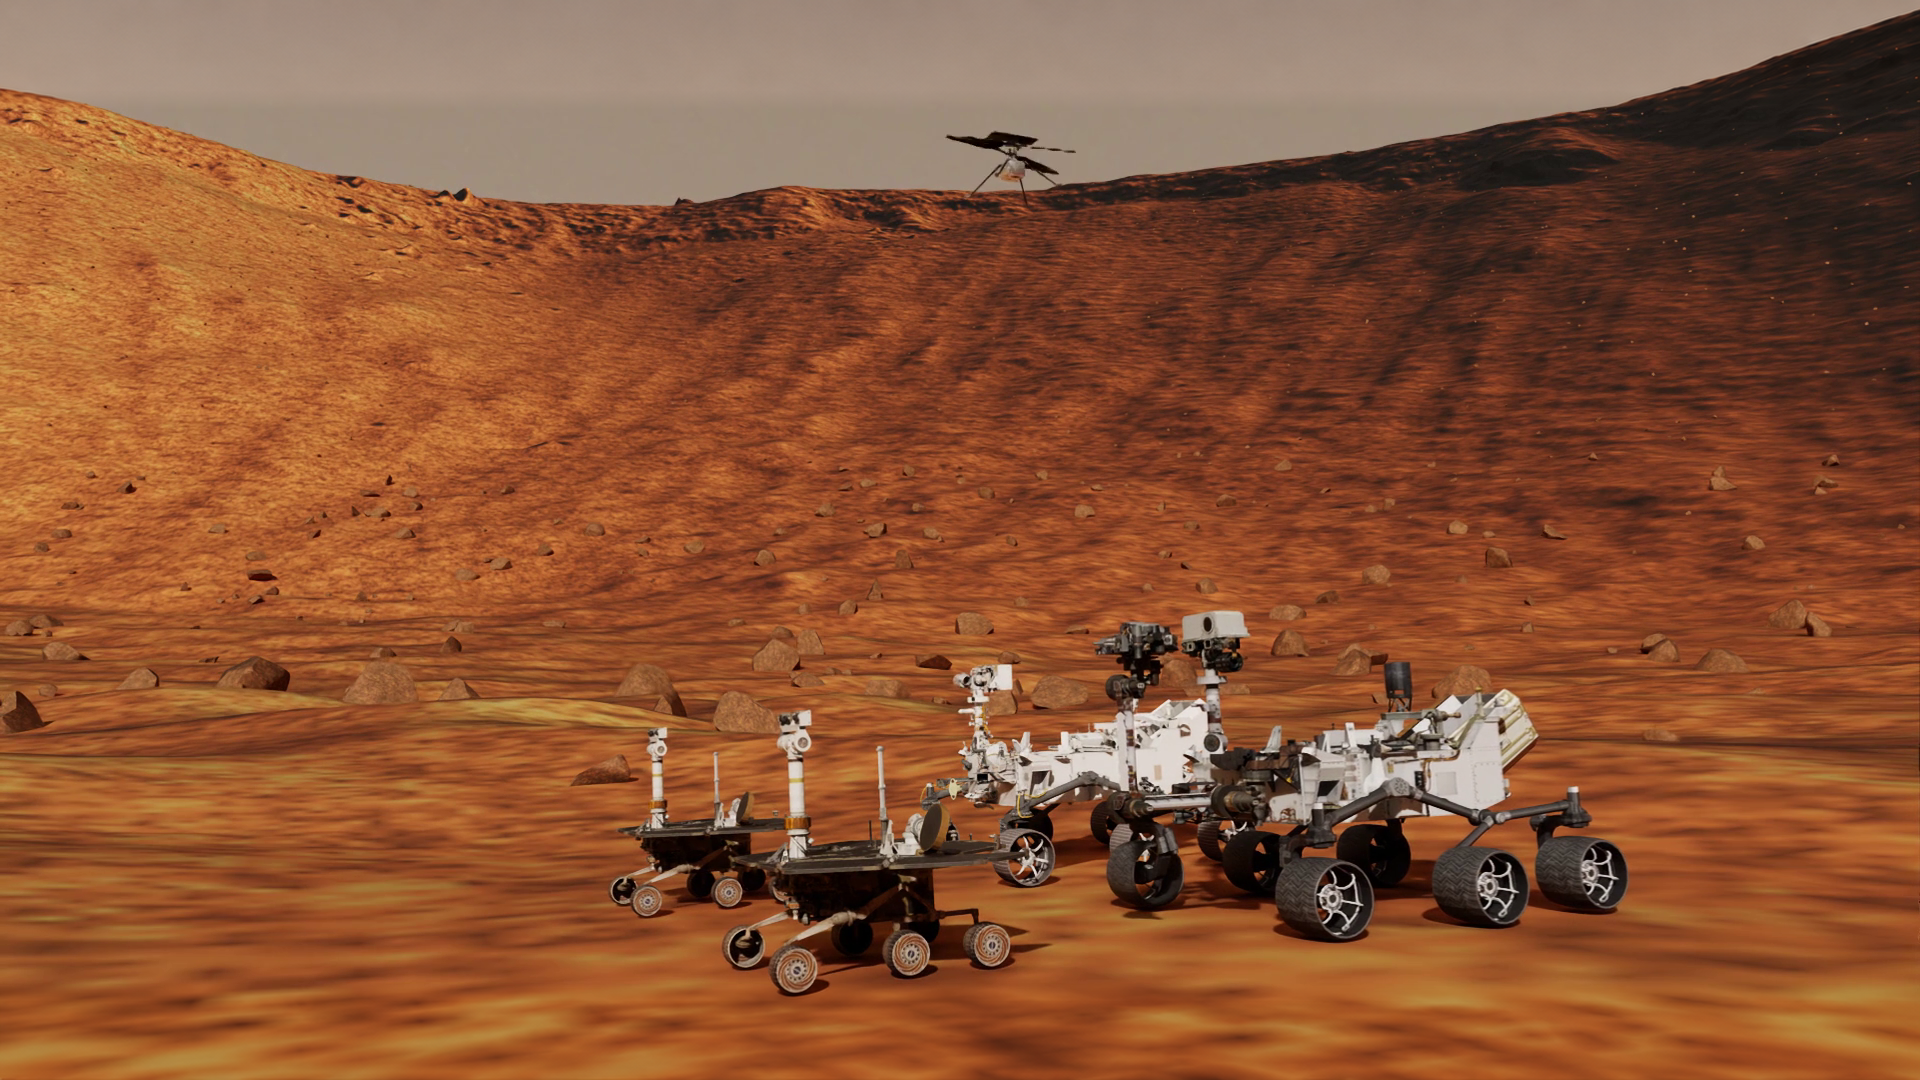
We present MarsLab, an open-source, ROS 2-native Mars rover simulator for repeatable autonomy evaluation. It provides customizable HiRISE-based terrain, lighting, dust, sensing, and rover motion, along with ground-truth pose data. It supports Perseverance, Curiosity, Opportunity, and Spirit rovers with a range of camera and LiDAR configurations.