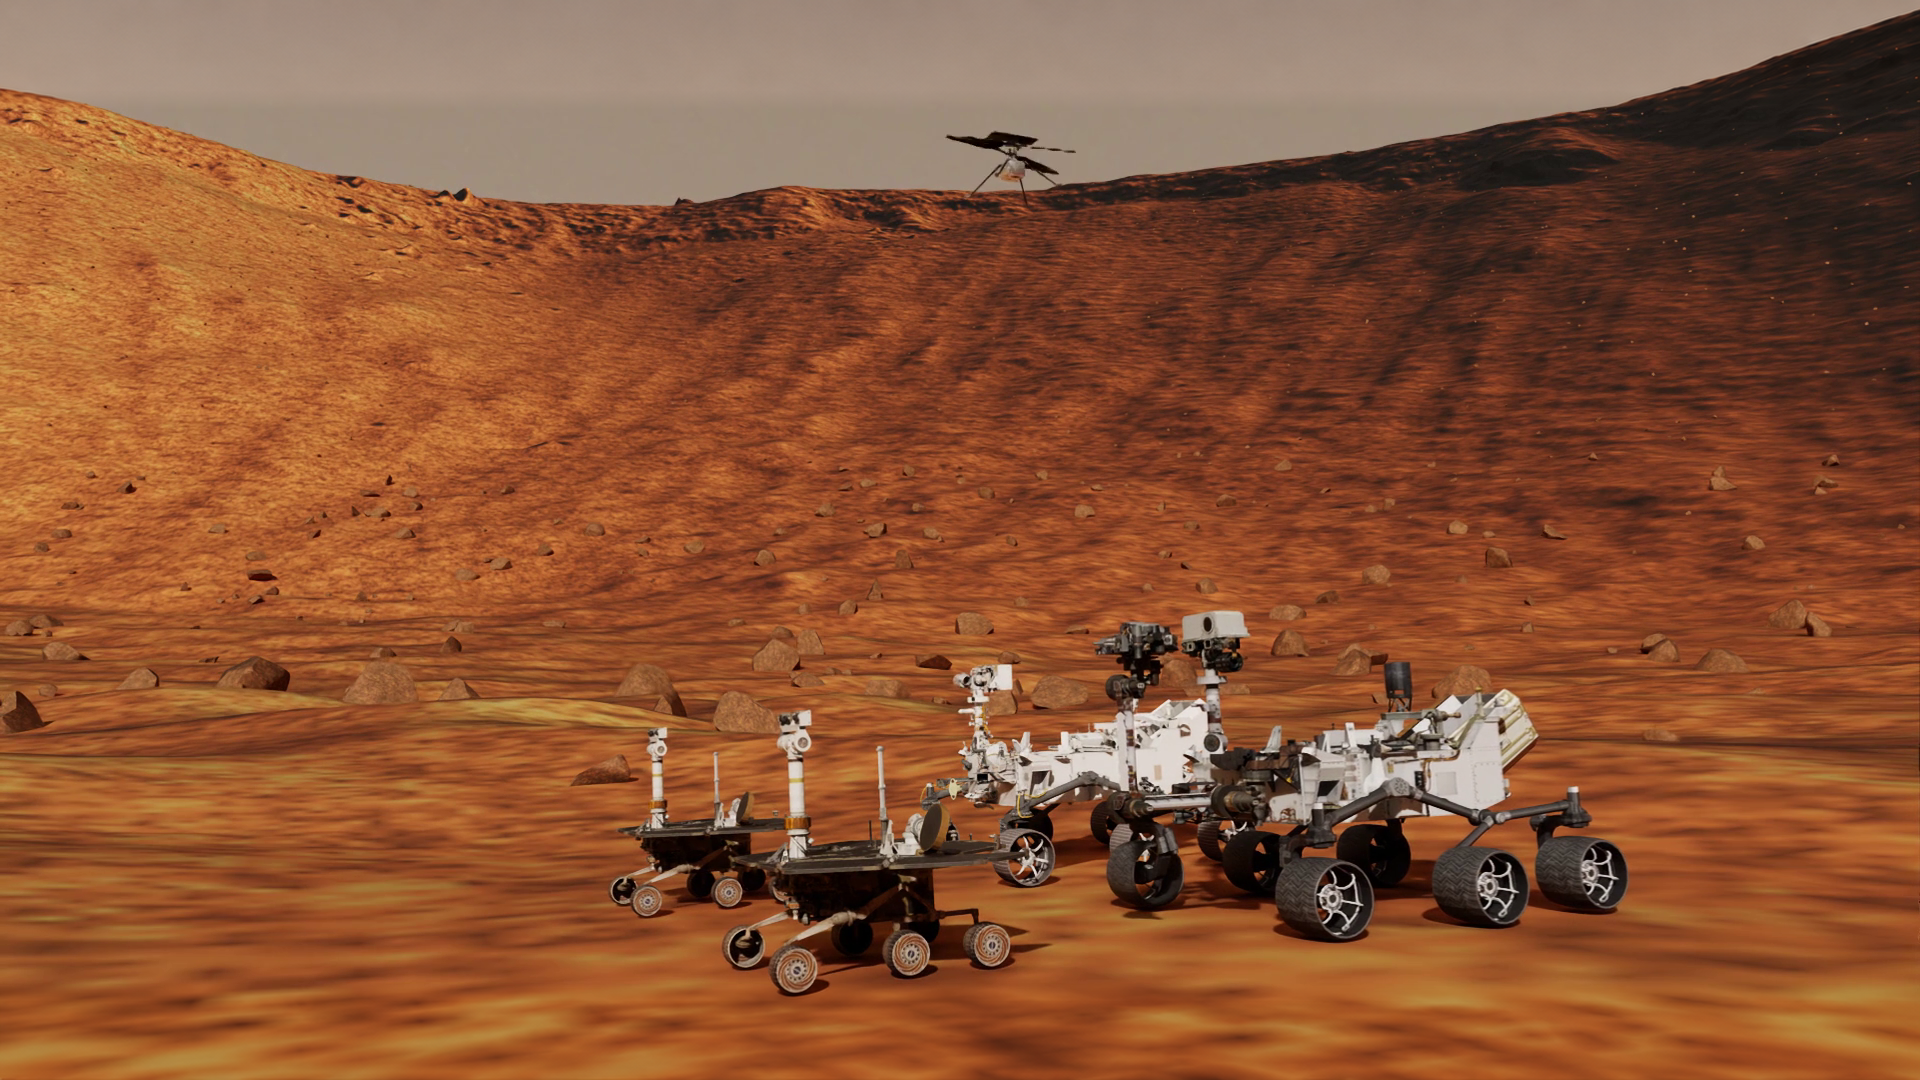
MarsLab
A ROS 2-native Mars rover simulator built on NVIDIA Isaac Sim, with continued upgrades planned including More realistic sensor simulation and Photorealistic Scene Generation.
Research in practice
Building tools to study how robots perceive, navigate, and operate beyond the lab.
A ROS 2-native Mars rover simulator built on NVIDIA Isaac Sim, with continued upgrades planned including More realistic sensor simulation and Photorealistic Scene Generation.
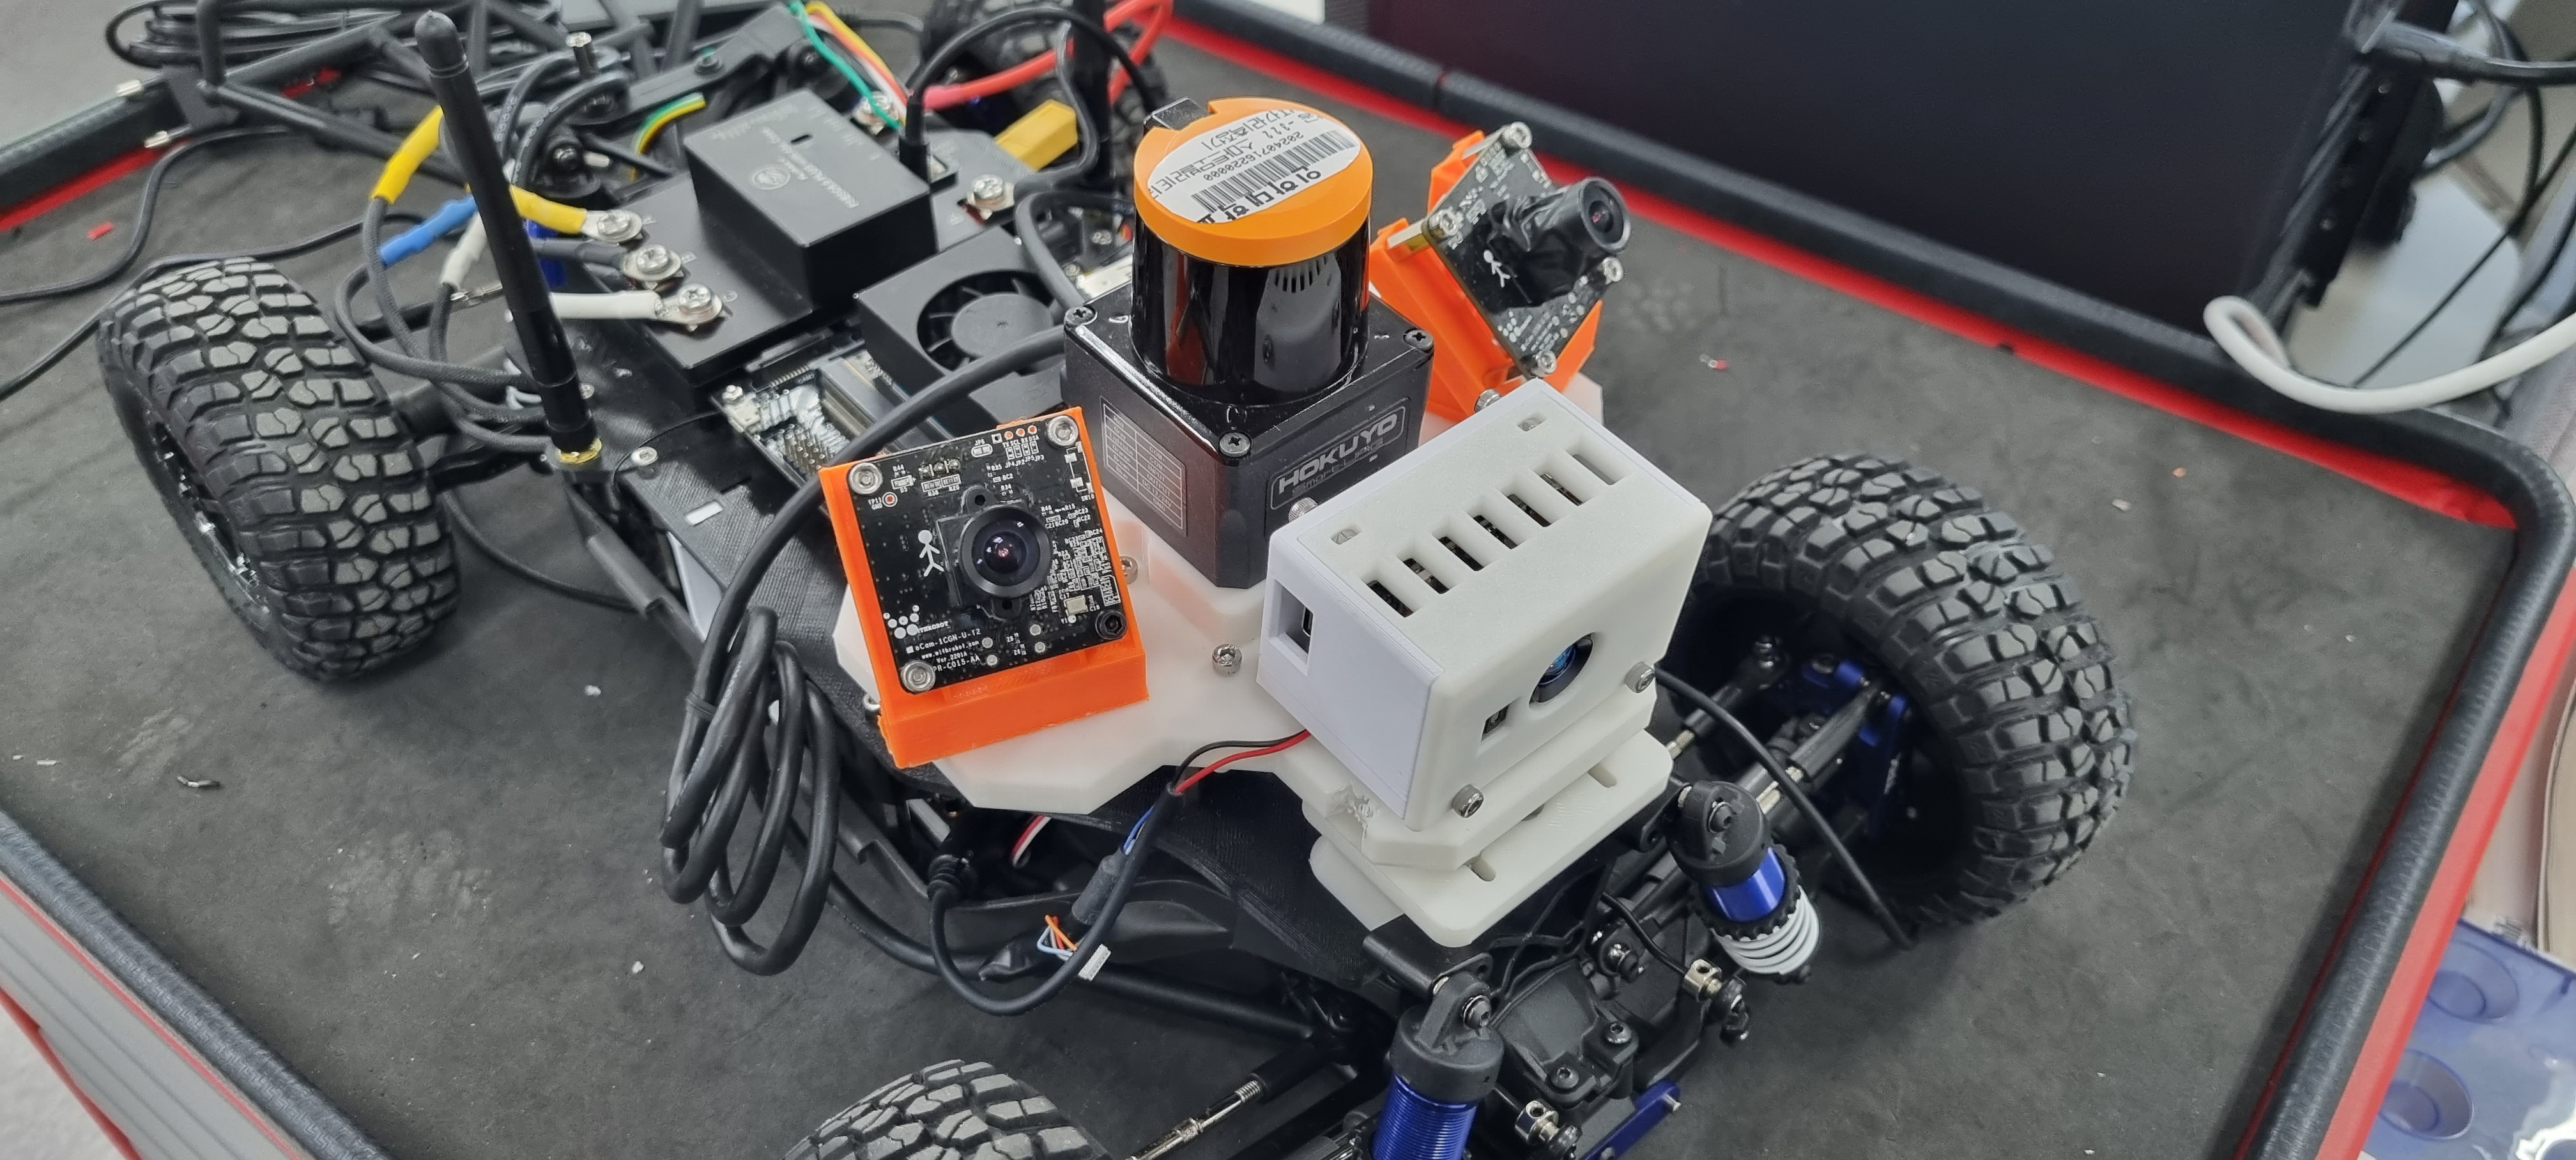
Autonomous racing software for RCV Formula, focused on SLAM and state estimation with 2D LiDAR, wheel odometry, and IMU measurements.
Former RCV Formula member; I am no longer affiliated with the team.
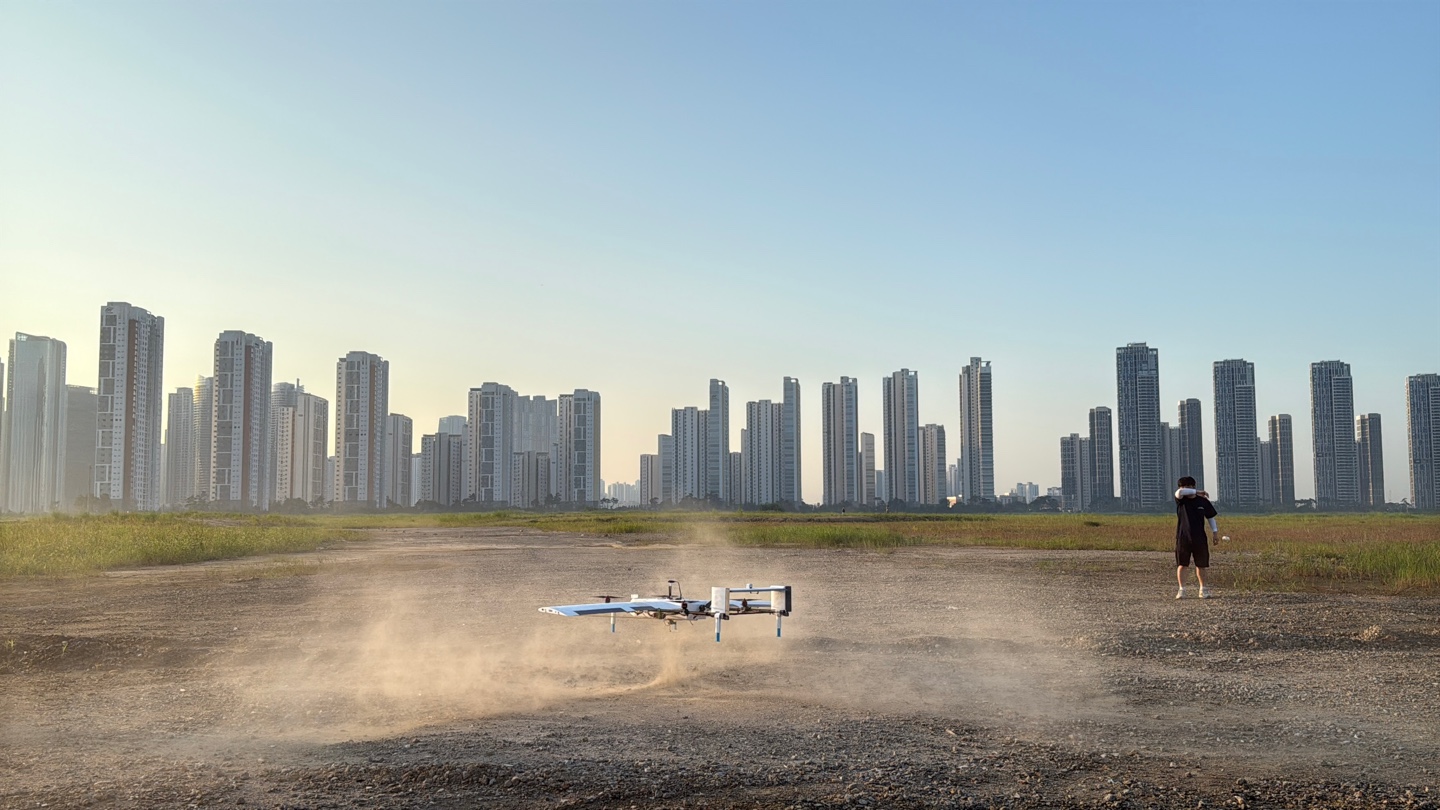
A custom VTOL aircraft using ROS 2 and PX4 for autonomous search-and-rescue missions in the 23rd Robot Aircraft Competition in 2025.
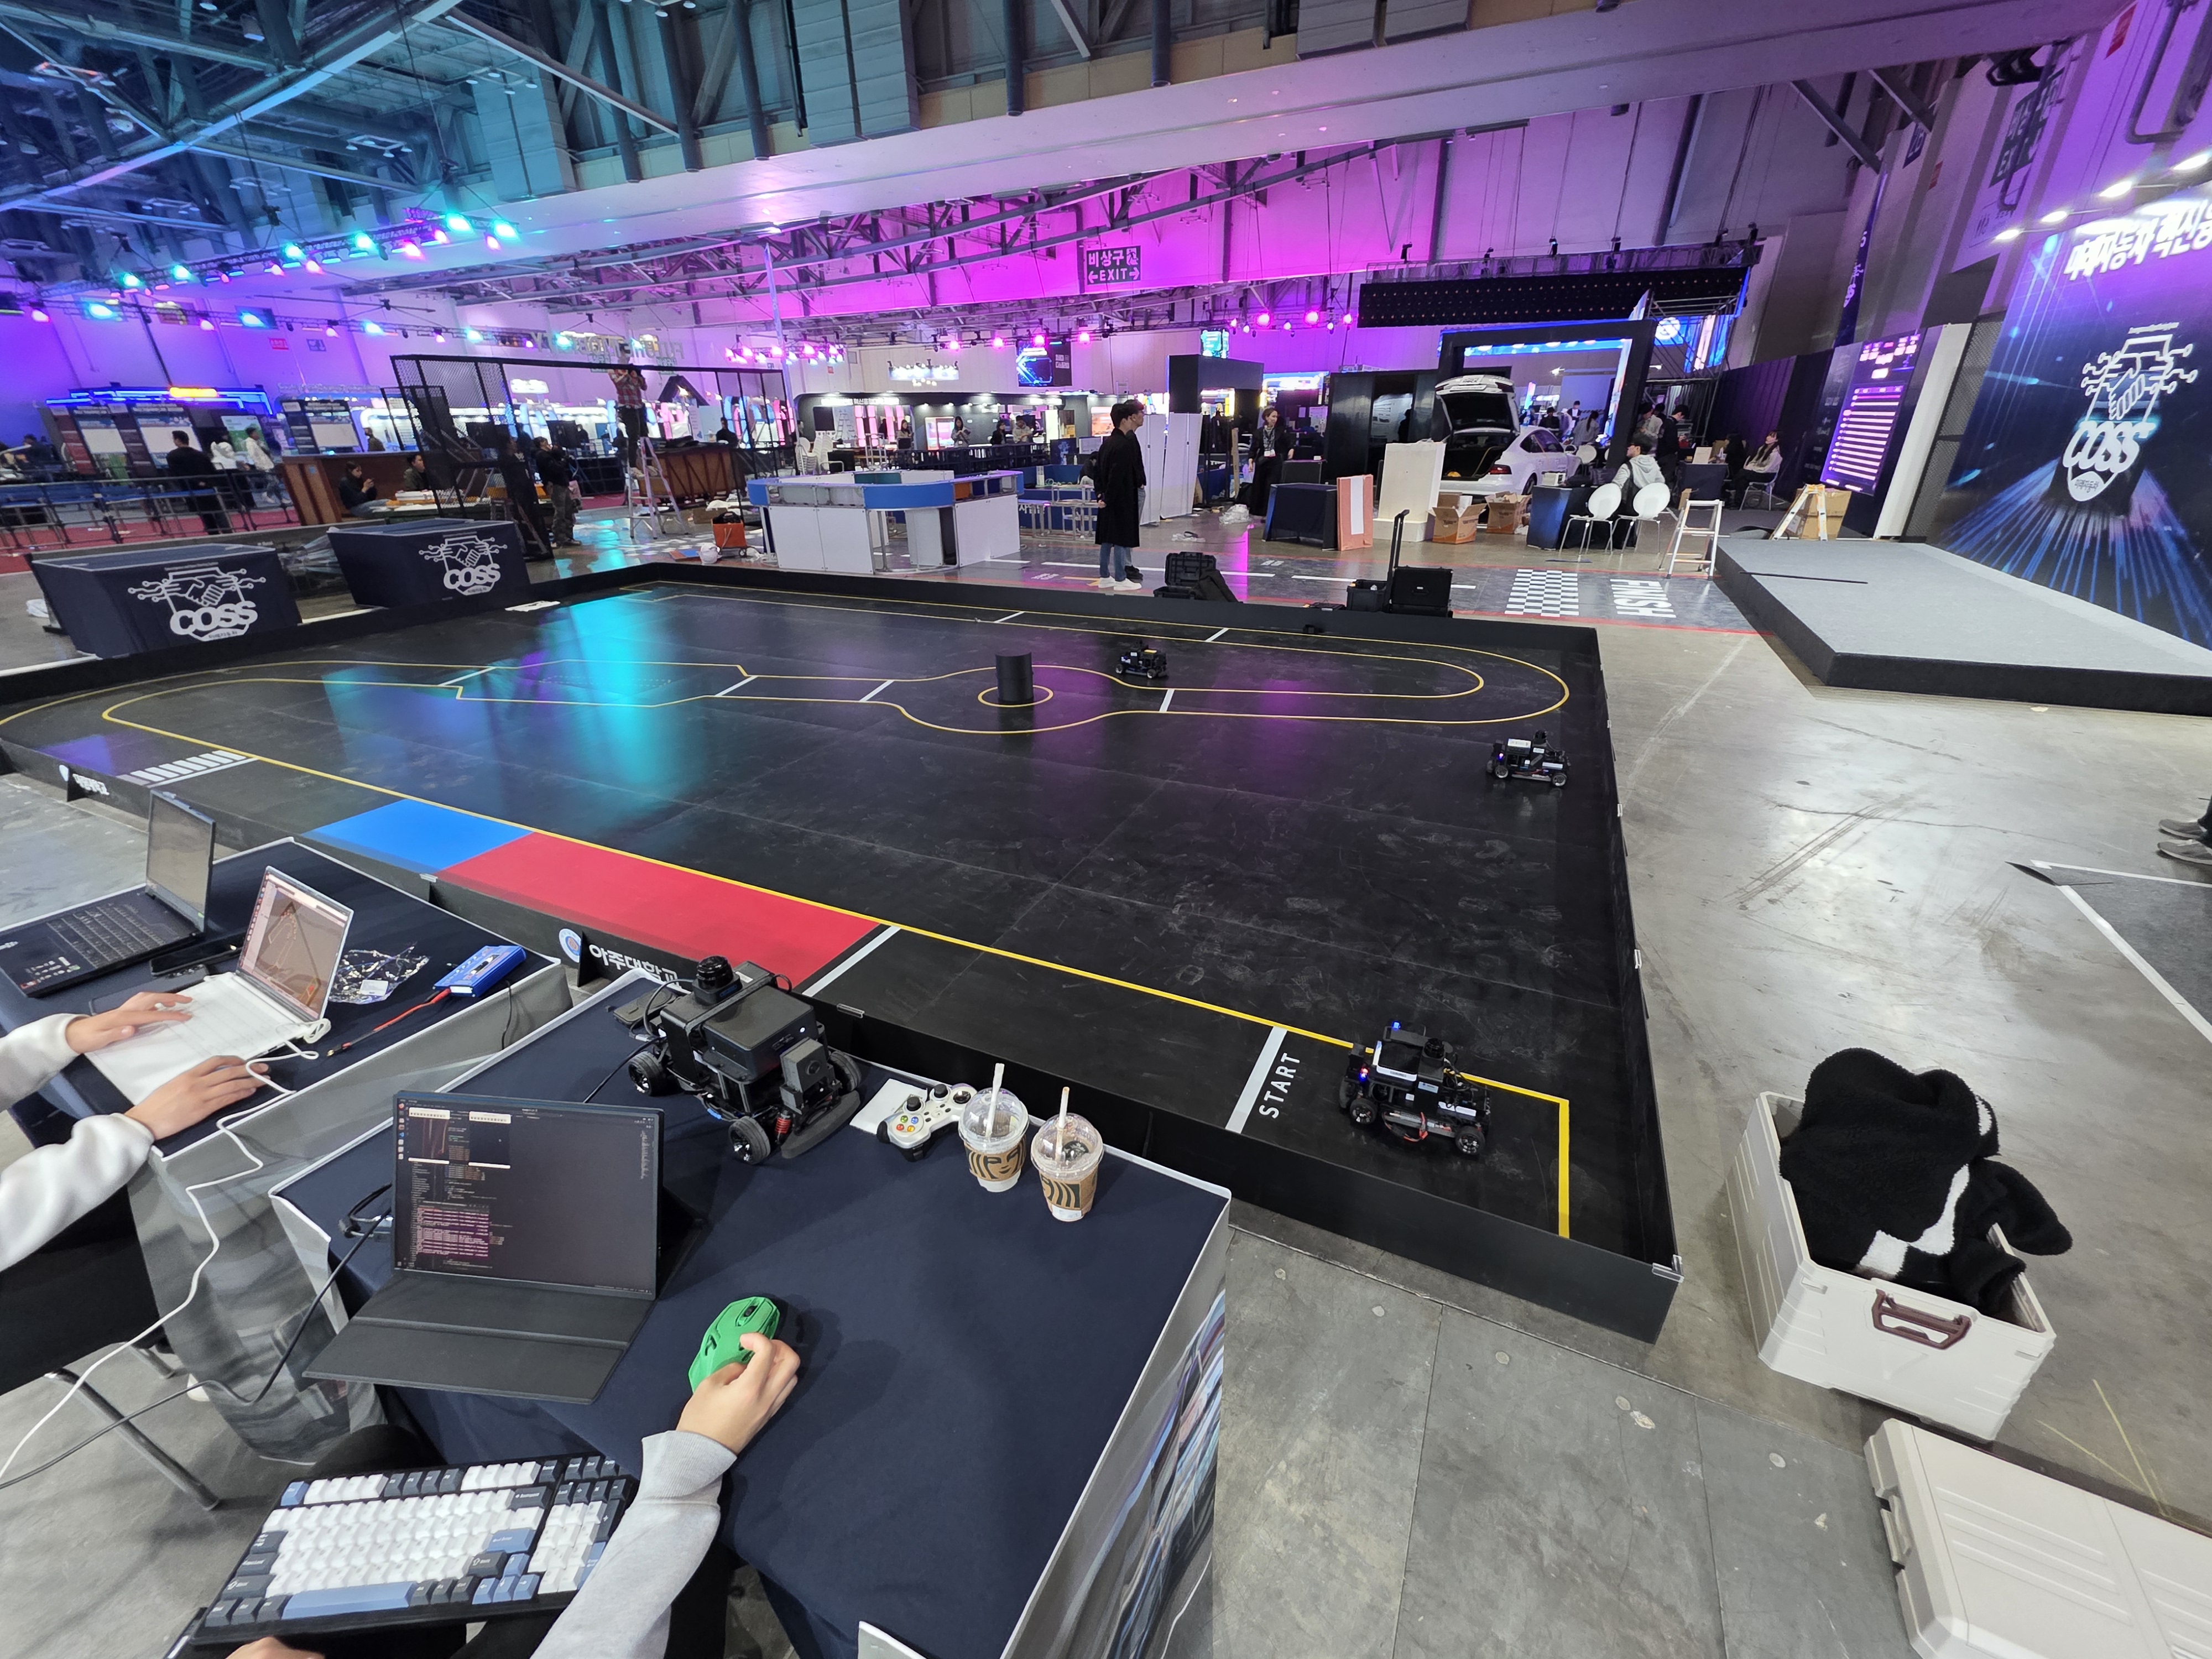
A scale-car autonomous driving project entered in the 2025 AUTO RACE competition.
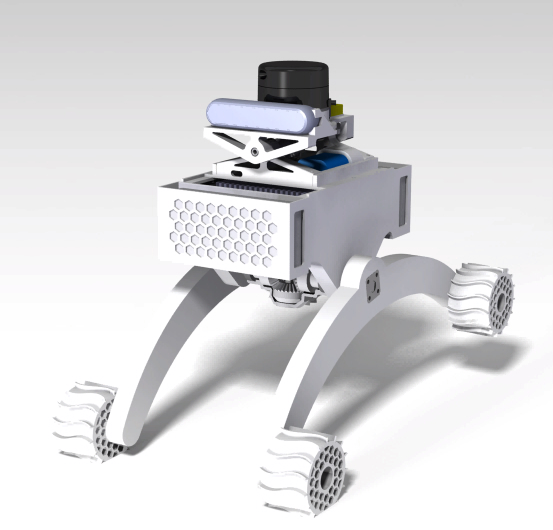
An autonomous exploration rover with a rocker chassis, an IMU-stabilized sensor platform, and a ROS 2 autonomy stack for uneven terrain.
Hanwha Aerospace CEO Award
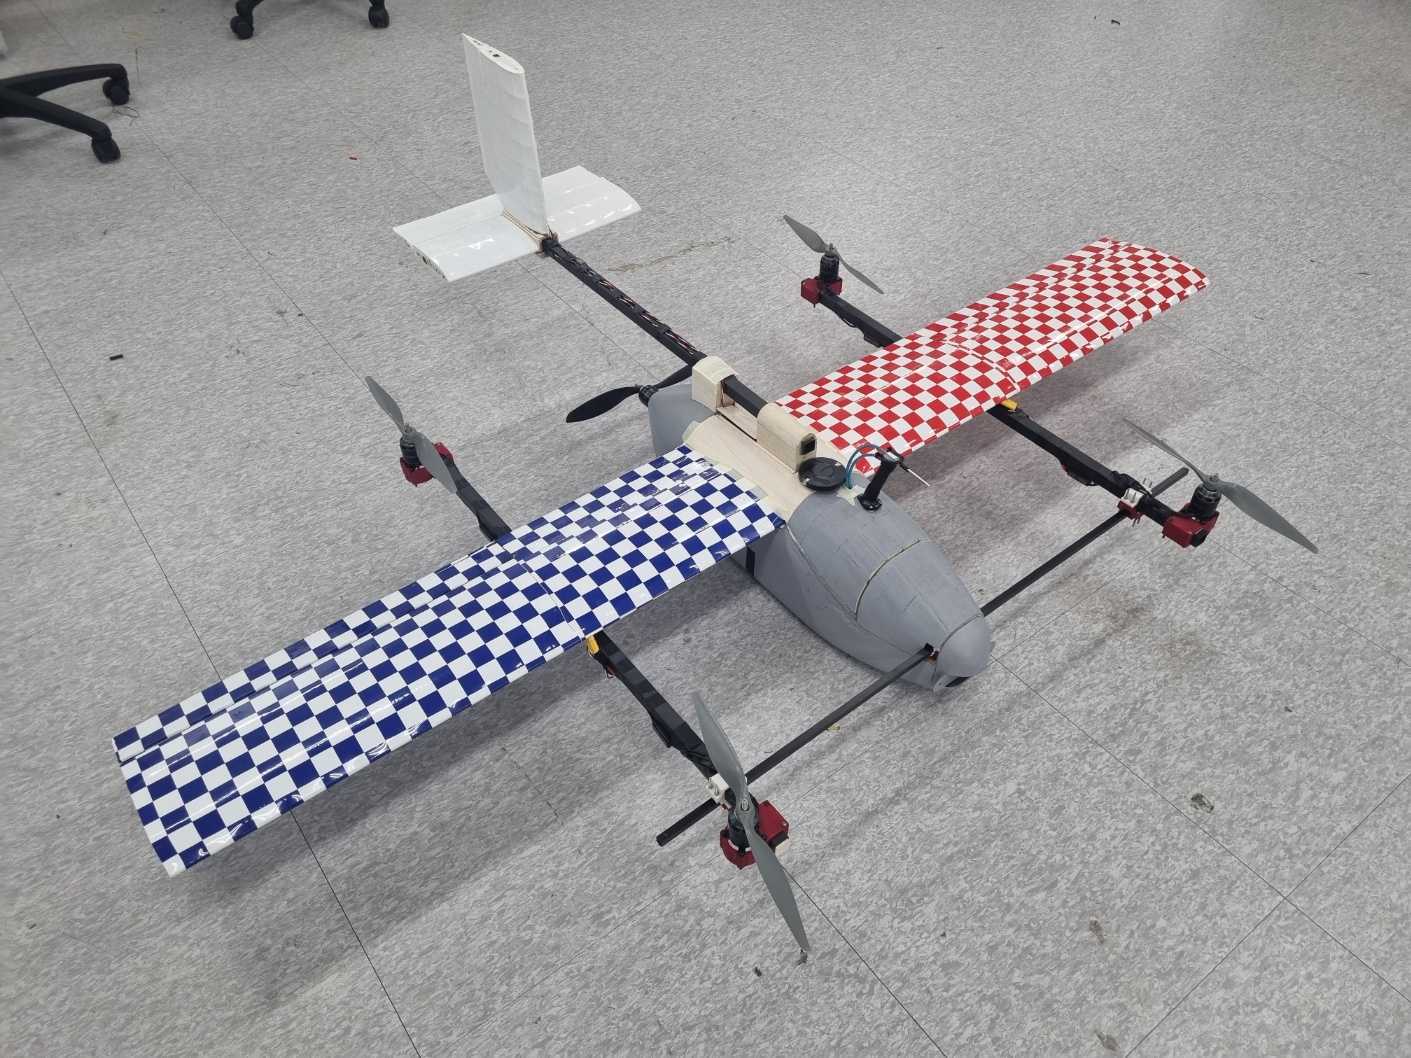
A custom VTOL aircraft built with ROS 2 and PX4 for autonomous flight in the 22nd Robot Aircraft Competition in 2024.