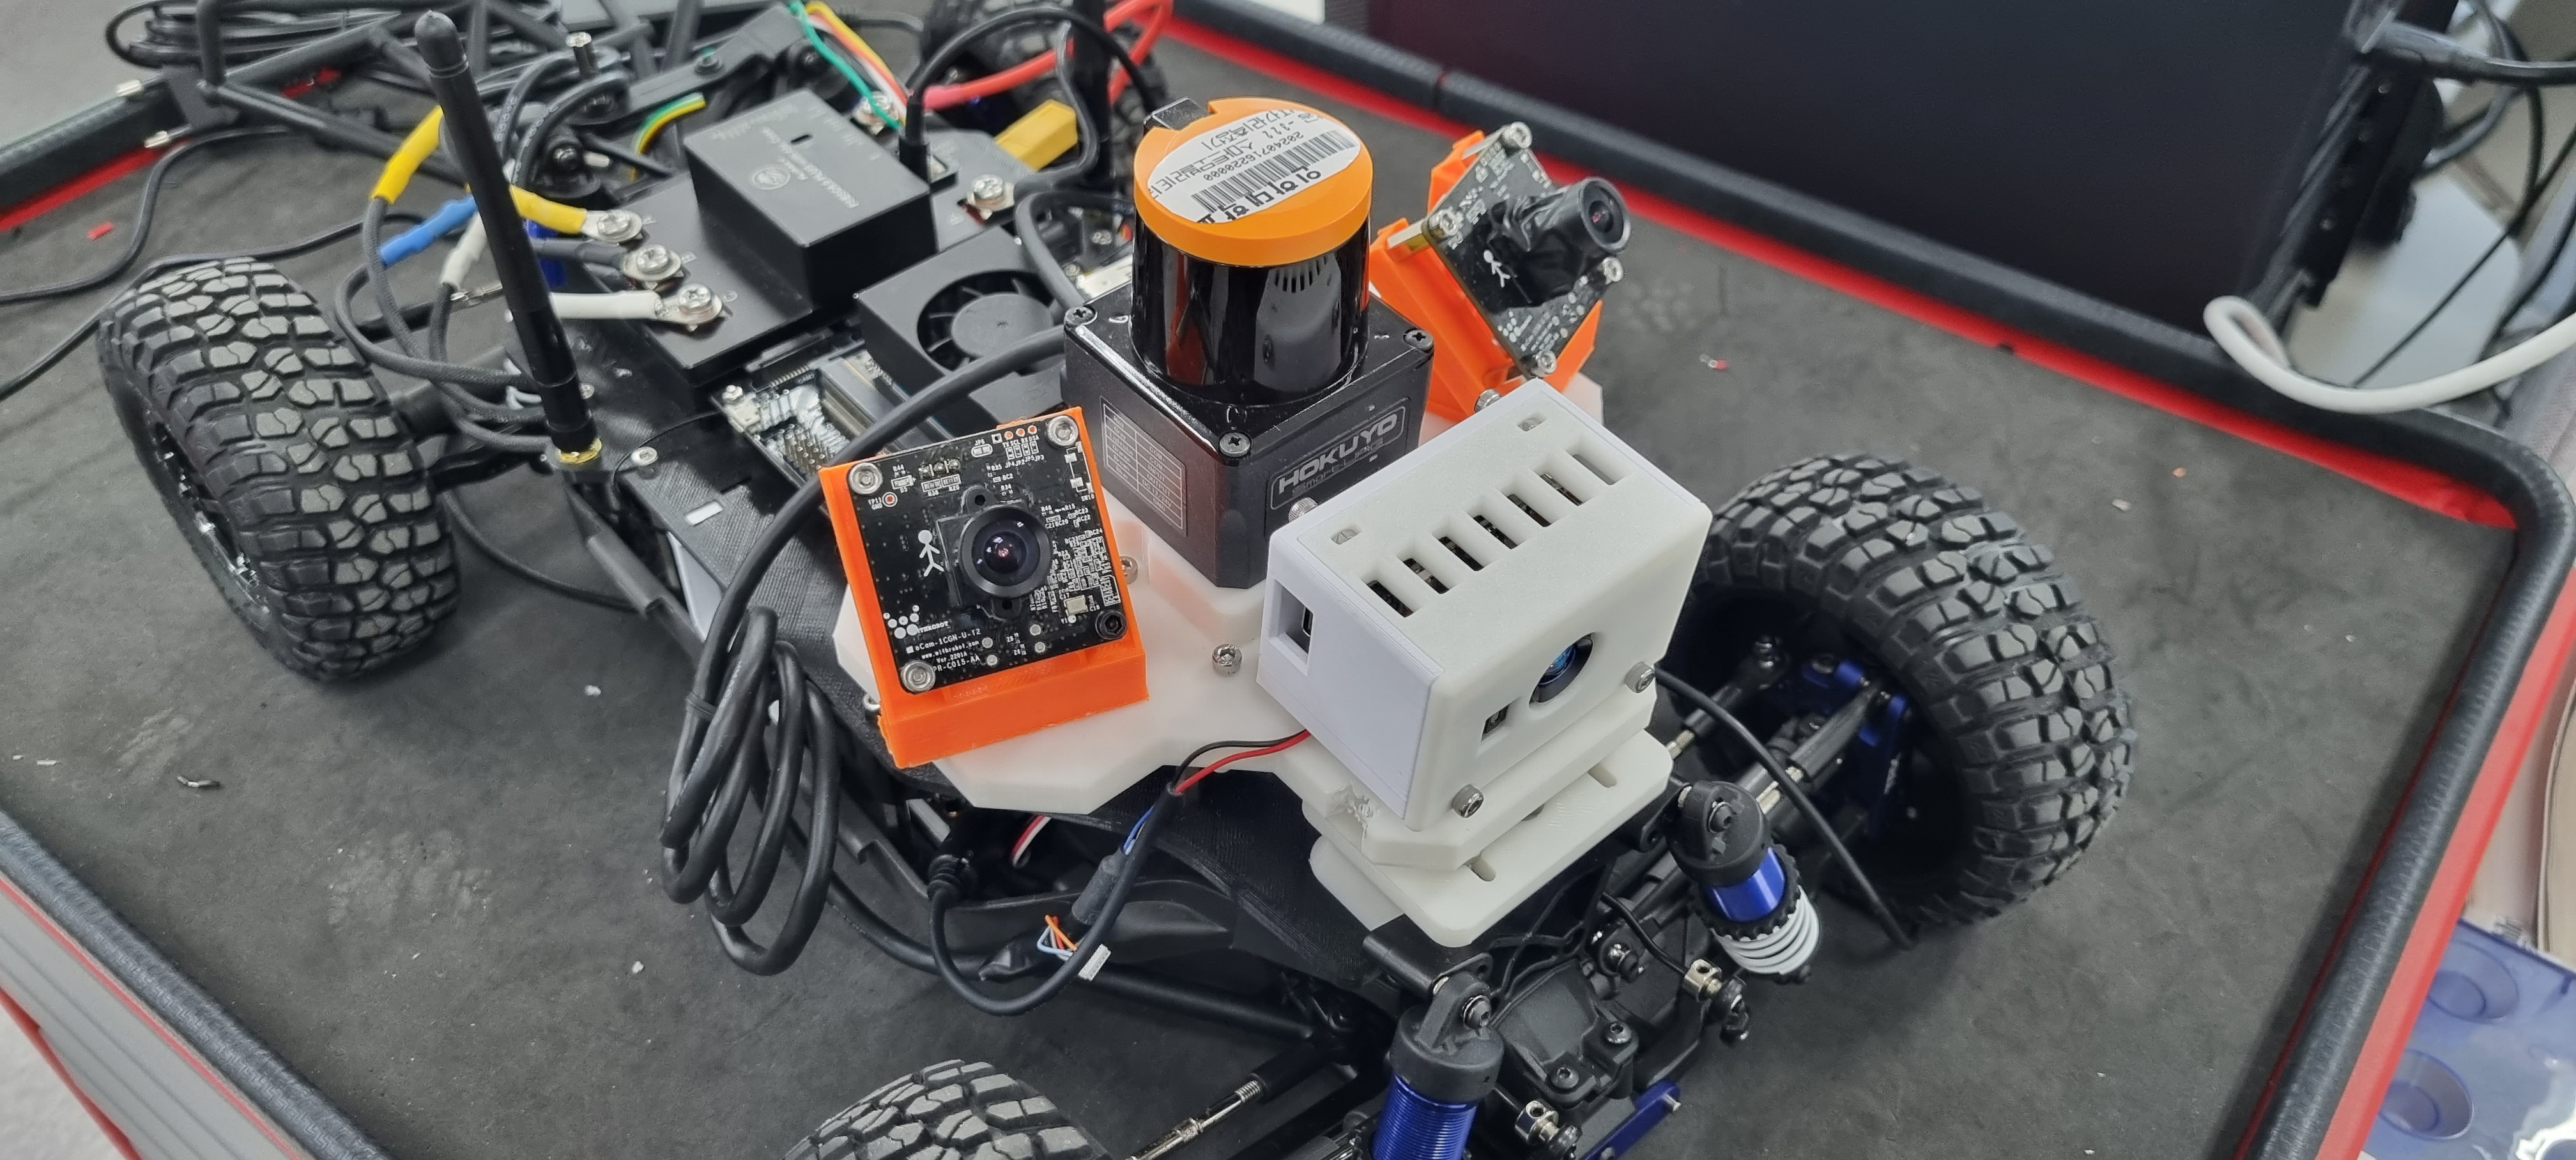
Overview
In 2025, I was responsible for software development with RCV Formula as we prepared for F1TENTH, the predecessor to today’s RoboRacer competition. Teams competed in autonomous racing using a prescribed vehicle platform.
The competition rules prohibited 3D LiDAR, so I developed SLAM and state estimation using 2D LiDAR, wheel odometry, and IMU measurements. To prepare for racing, I also developed a custom Gazebo simulator and used it to validate the algorithms.
Team and code
I am a former team member and am no longer affiliated with RCV Formula.
The simulation code is available in the Humble branch of robotics-sim-tutorial-kr.